Japanese
English
- 有料閲覧
PPV購入案内
1,320円 (1,200円+税10%) こちらは、317ページから322ページの文献です。購入には医書.jp本会員登録が必要です。
会員登録完了後に改めて上記「購入サイトへ」を選択してください。
または「購入サイトへ」選択後に「購入ログイン」、「新規会員登録」の順に進んでください。
会員登録について詳しくはをご確認ください。
- Abstract 文献概要
- 1ページ目 Look Inside
- 参考文献 Reference
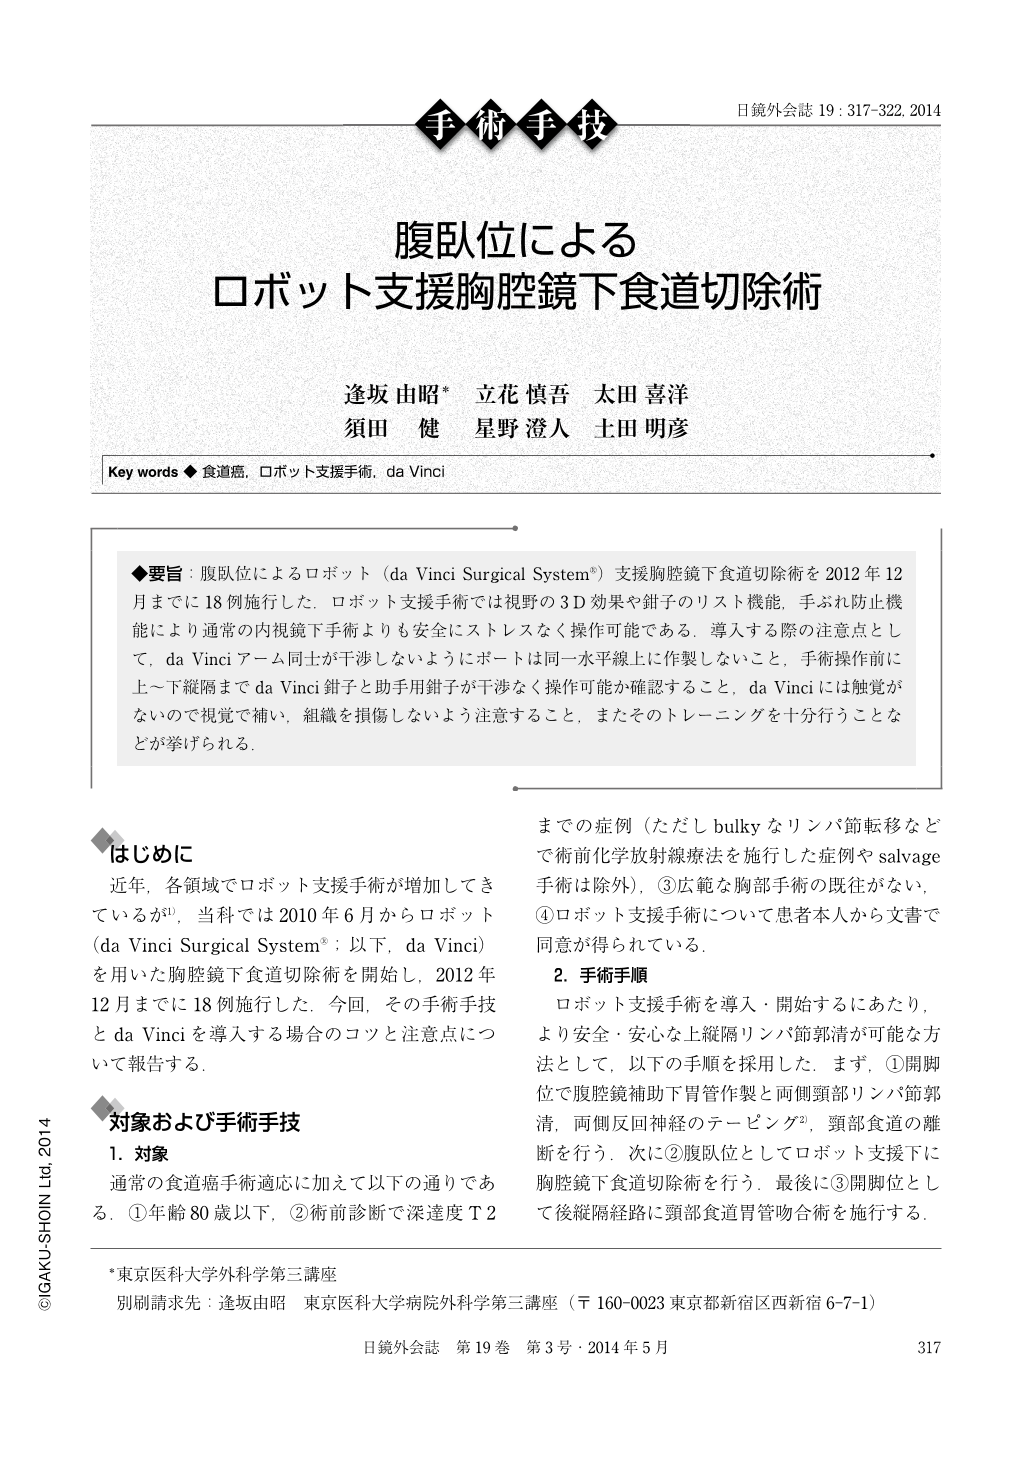
◆要旨:腹臥位によるロボット(da Vinci Surgical System®)支援胸腔鏡下食道切除術を2012年12月までに18例施行した.ロボット支援手術では視野の3D効果や鉗子のリスト機能,手ぶれ防止機能により通常の内視鏡下手術よりも安全にストレスなく操作可能である.導入する際の注意点として,da Vinciアーム同士が干渉しないようにポートは同一水平線上に作製しないこと,手術操作前に上~下縦隔までda Vinci鉗子と助手用鉗子が干渉なく操作可能か確認すること,da Vinciには触覚がないので視覚で補い,組織を損傷しないよう注意すること,またそのトレーニングを十分行うことなどが挙げられる.
As of December 2012, we had performed robot (da Vinci Surgical System®)-assisted thoracoscopic esophagectomy in a prone position in a total of 18 cases. With 3-D visual effects, forceps with wrist movements, and a handshake-preventive function, robot-assisted surgeries are performed more safely without stress, compared to conventional endoscopic surgeries. Points for appropriately using this system may include: not creating multiple ports on the same horizontal plane to prevent da Vinci arms from mutually interfering; confirming the applicability of da Vinci and assistant forceps without mutual interference in the superior to inferior mediastinum; compensating for the lack of a tactile sense with sight to avoid damaging tissues; and training sufficiently for this.
Copyright © 2014, JAPAN SOCIETY FOR ENDOSCOPIC SURGERY All rights reserved.