Japanese
English
- 有料閲覧
PPV購入案内
1,320円 (1,200円+税10%) こちらは、769ページから774ページの文献です。購入には医書.jp本会員登録が必要です。
会員登録完了後に改めて上記「購入サイトへ」を選択してください。
または「購入サイトへ」選択後に「購入ログイン」、「新規会員登録」の順に進んでください。
会員登録について詳しくはをご確認ください。
- Abstract 文献概要
- 1ページ目 Look Inside
- 参考文献 Reference
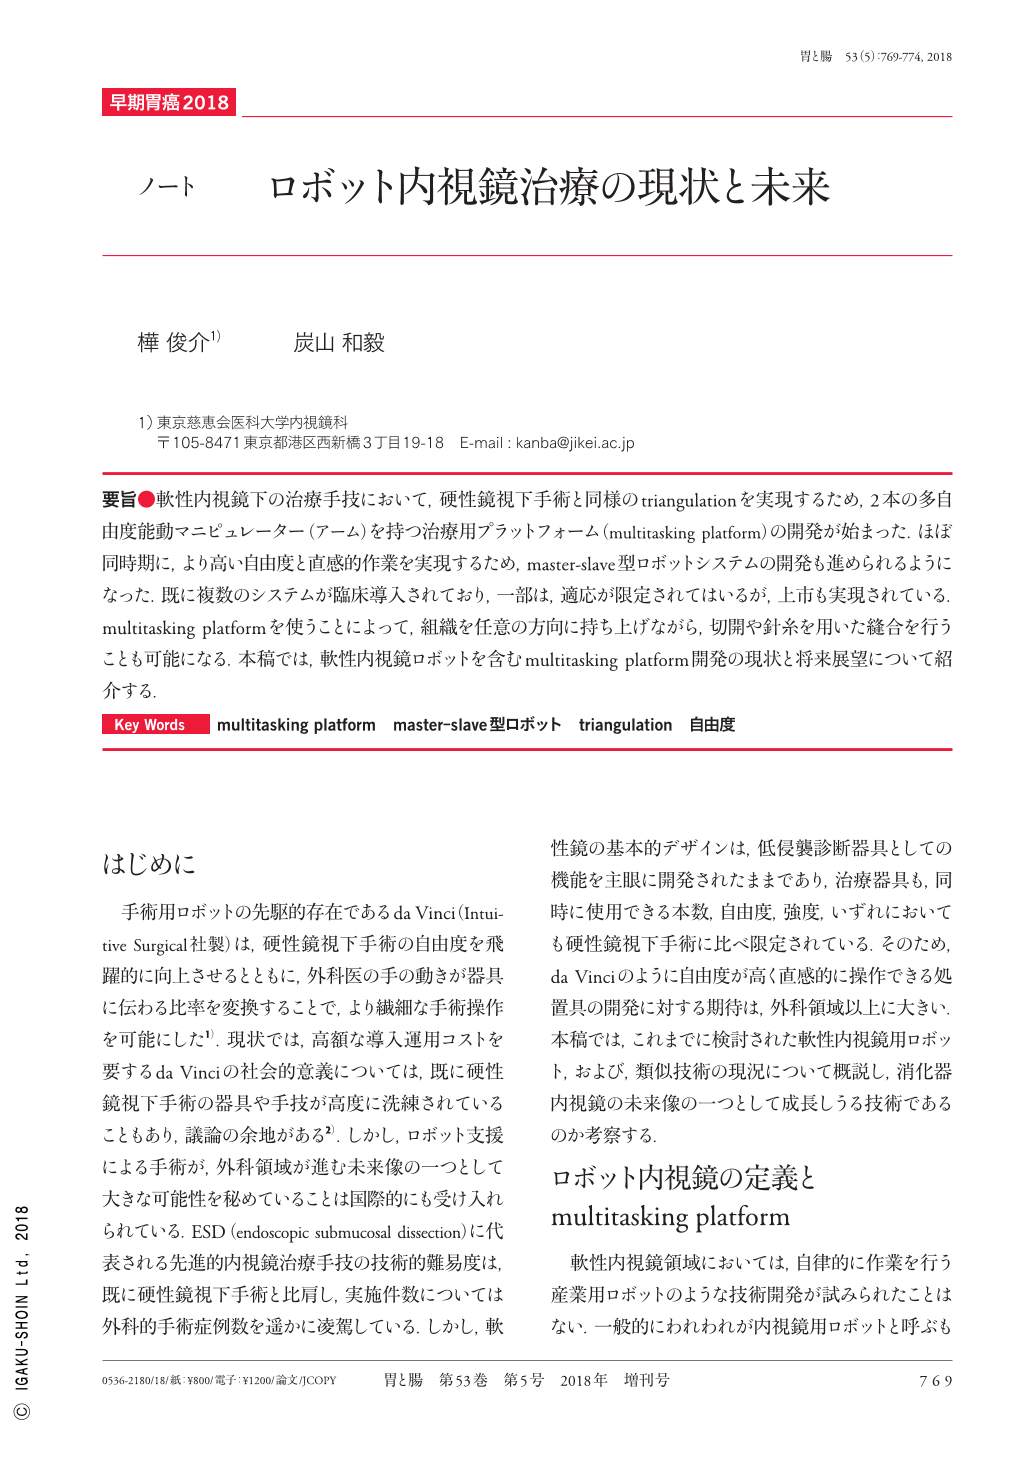
要旨●軟性内視鏡下の治療手技において,硬性鏡視下手術と同様のtriangulationを実現するため,2本の多自由度能動マニピュレーター(アーム)を持つ治療用プラットフォーム(multitasking platform)の開発が始まった.ほぼ同時期に,より高い自由度と直感的作業を実現するため,master-slave型ロボットシステムの開発も進められるようになった.既に複数のシステムが臨床導入されており,一部は,適応が限定されてはいるが,上市も実現されている.multitasking platformを使うことによって,組織を任意の方向に持ち上げながら,切開や針糸を用いた縫合を行うことも可能になる.本稿では,軟性内視鏡ロボットを含むmultitasking platform開発の現状と将来展望について紹介する.
To perform more complicated interventional procedures with a flexible endoscope, to date, a variety of multitasking platforms equipped with two DOF(multidegree-of-freedom)manipulators(arms)have been developed. During this period, the technical feasibility of robotized multitasking platforms has been explored to add more DOFs to the arms and enable a more intuitive manipulation of the system. Recently, a few of these platforms were made commercially available for selective indications. In this article, we tried to summarize the current research activities on the multitasking platforms, including robotized systems, and discussed the future perspectives of this novel technology.
Copyright © 2018, Igaku-Shoin Ltd. All rights reserved.