Japanese
English
特集 起立と歩行
起立から歩行へ―中枢神経系の姿勢保持機構
Integration of neuronal mechanisms related to locomotor control and postural control.
森 茂美
1
Shigemi MORI
1
1旭川医科大学生理学第二講座
1Department of Physiology, Asahikawa Medical College
pp.173-188
発行日 1991年4月10日
Published Date 1991/4/10
DOI https://doi.org/10.11477/mf.1431900119
- 有料閲覧
PPV購入案内
1,320円 (1,200円+税10%) こちらは、173ページから188ページの文献です。
PPV(ペイ・パー・ビュー)とは、論文(記事)単位で購入・閲覧ができるサービスです。
購入には医書.jp本会員登録が必要です。
会員登録完了後に改めて上記「購入サイトへ」を選択してください。
または「購入サイトへ」選択後に「購入ログイン」、「新規会員登録」の順に進んでください。
会員登録について詳しくはをご確認ください。
購入には医書.jp本会員登録が必要です。
会員登録完了後に改めて上記「購入サイトへ」を選択してください。
または「購入サイトへ」選択後に「購入ログイン」、「新規会員登録」の順に進んでください。
会員登録について詳しくはをご確認ください。
- Abstract 文献概要
- 1ページ目 Look Inside
はじめに
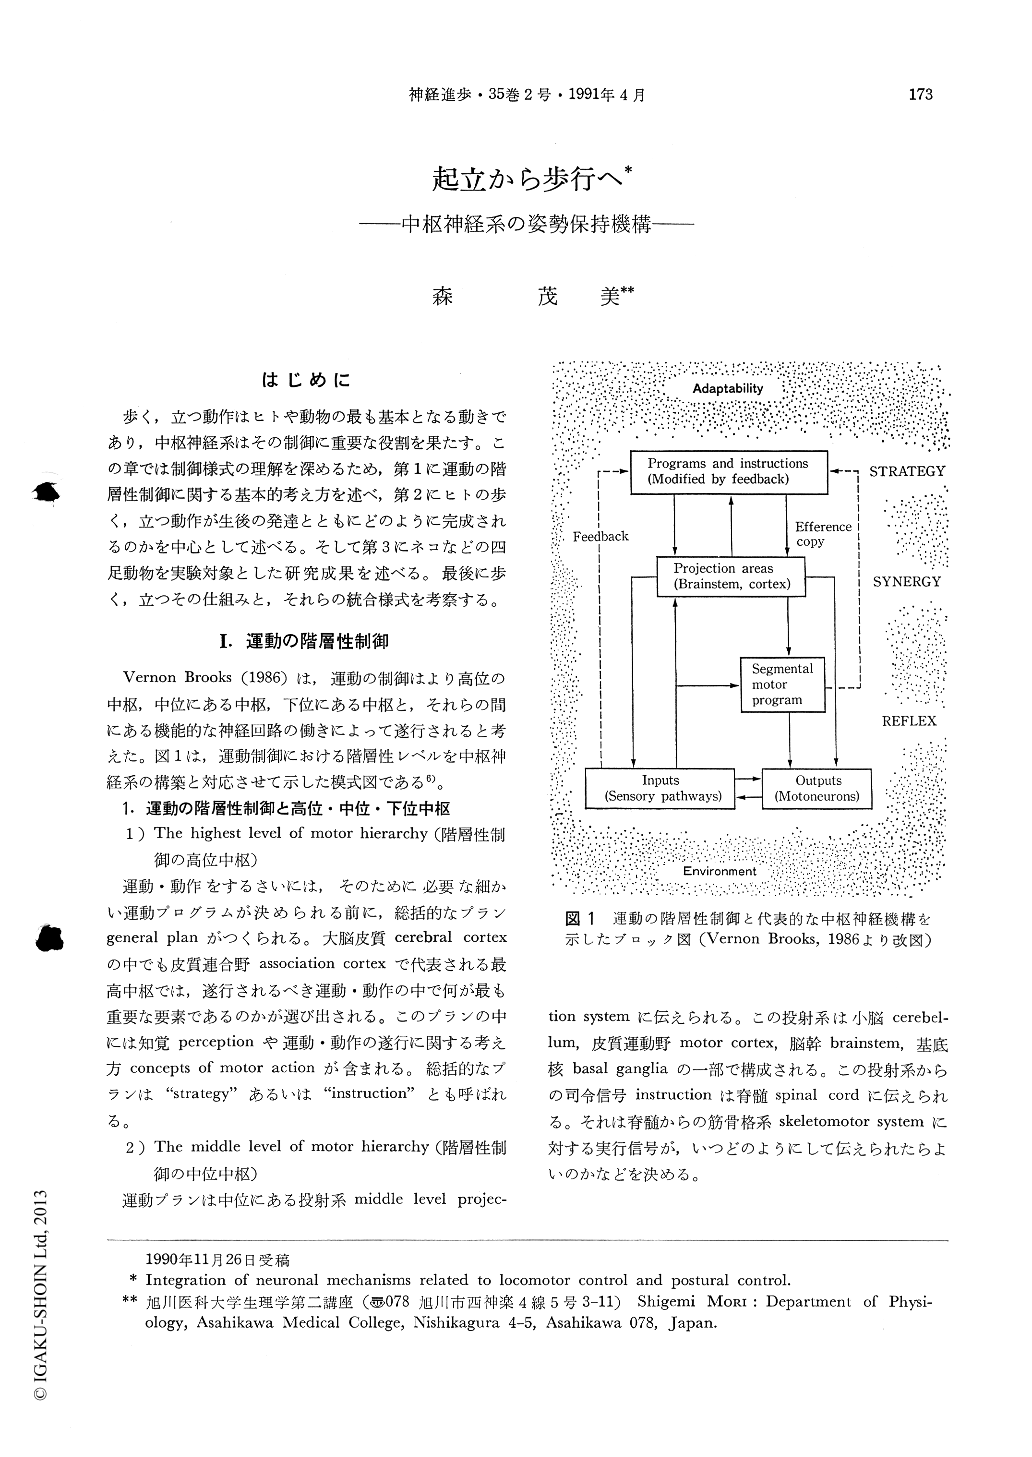
歩く,立つ動作はヒトや動物の最も基本となる動きであり,中枢神経系はその制御に重要な役割を果たす。この章では制御様式の理解を深めるため,第1に運動の階層性制御に関する基本的考え方を述べ,第2にヒトの歩く,立つ動作が生後の発達とともにどのように完成されるのかを中心として述べる。そして第3にネコなどの四足動物を実験対象とした研究成果を述べる。最後に歩く,立つその仕組みと,それらの統合様式を考察する。
To initiate and terminate locomotor movements both in the biped and in the quadruped, a smooth transition from and to standing is necessary, standing being another active motor behavior. During locomotion, an animal controls without interruption the speed and direction of the locomotion, is able to circumvent all obstacles and anticipates necessary conditions, and deals with unexpected perturba-tions. Locomotion and upright standing posture are the two basic motor behaviors common to the bipeds and quardupeds.
Copyright © 1991, Igaku-Shoin Ltd. All rights reserved.